Java on hardware
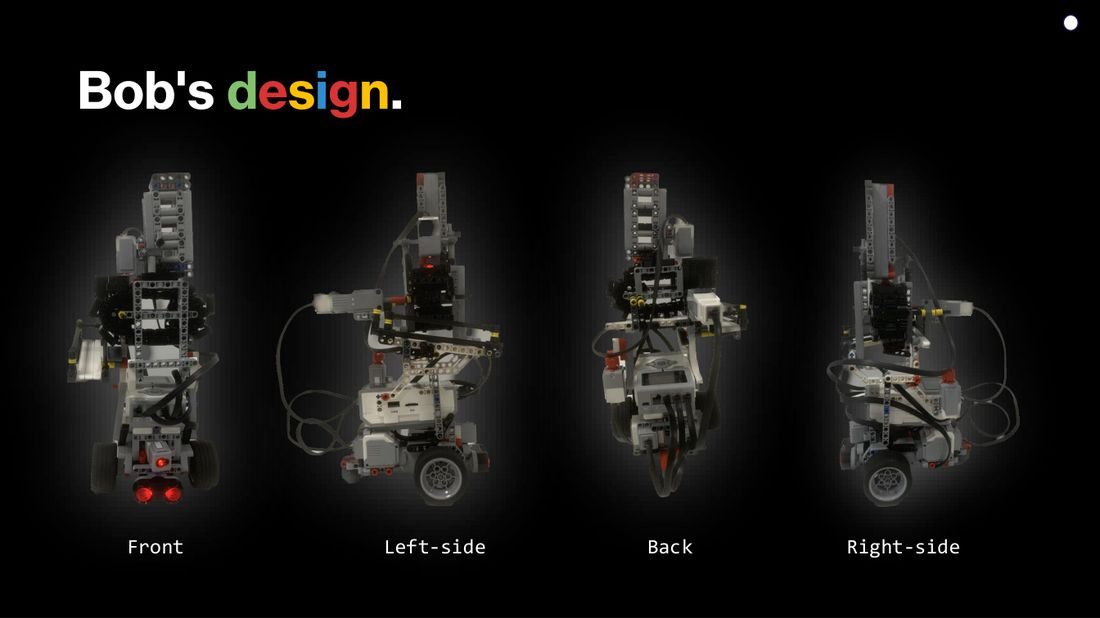
Programmed in Java with LeJOS, running on the LEGO EV3 brick.
A LEGO robot that sorts marbles by colour.
An autonomous LEGO EV3 robot programmed in Java with LeJOS. It reads a marble’s colour, finds the matching container and drops the marble in, with over 90% colour-detection accuracy. I worked on the sensor logic and navigation.
Programmed in Java with LeJOS, running on the LEGO EV3 brick.
Colour readings turned into reliable decisions, with over 90% detection accuracy after calibration.
Seven behaviours under one arbitrator, from emergency stop to marble detection, plus explicit states.
Finds containers with the distance sensor and drives to the one that matches the colour.
Sort coloured marbles into matching containers with no human help.
With the team: a conveyor, a ramp and two sensors. My part was reading colour reliably, finding containers and getting Bob between them.
An autonomous sorter with over 90% colour-detection accuracy. Adding explicit states stopped behaviours firing out of turn.
Select any image to see it larger.
 Java
 LeJOSLEGO Mindstorms EV3Colour and distance sensors