Search algorithms
A* over (row, col, sol). Each sol has a drive budget, so the best route can wait out a dust storm instead of driving into it.
From any point on Mars to the nearest water, priced in sols.
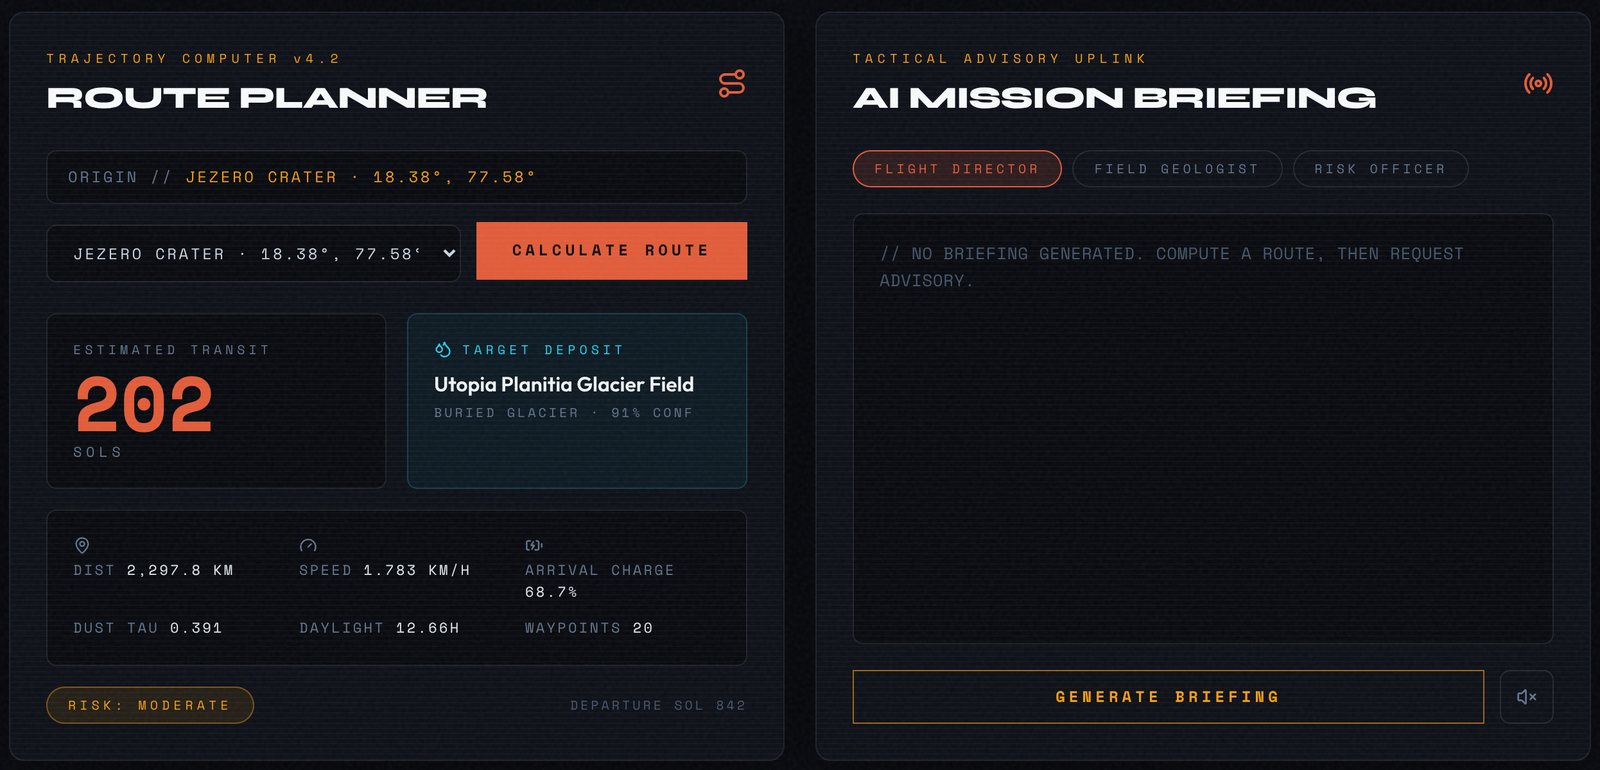
A route-planning engine that searches space and time for the fastest safe traverse to water under terrain, daylight and dust constraints, paired with a mission-control web app: a GLSL-shader 3D Mars, a FastAPI backend and AI briefings streamed live.
A* over (row, col, sol). Each sol has a drive budget, so the best route can wait out a dust storm instead of driving into it.
MOLA-style elevation and AI4Mars-style terrain classes make the cost map; MARCI-style dust opacity drives a solar power model.
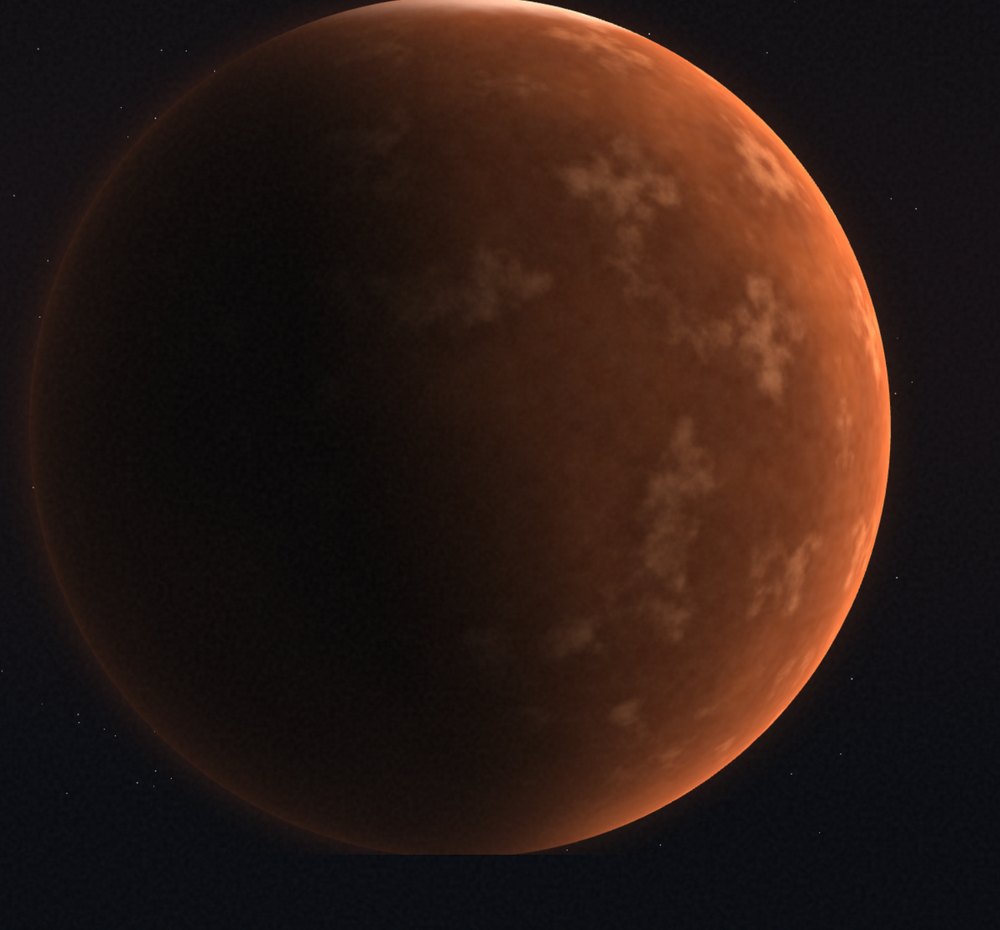
A custom GLSL shader planet in react-three-fiber: noise terrain, a day/night terminator and an atmosphere rim. Click it to set a start point.
FastAPI and MongoDB behind the app; OpenAI briefings in three personas, streamed token by token over server-sent events.
Nearest water is not soonest water. A solar rover’s range depends on dust, daylight and the ground under it, so ranking by distance picks the wrong deposit.
A planner that answers in sols: slopes and rocks as hard limits, a dust-driven daily drive budget, and A* over position and time. Then a mission-control app around it.
In the demo run the planner reached water in 9.3 sols, holding still for 4 sols through a dust storm, and ranked every reachable deposit by time.
Select any image to see it larger.
 Python
 NumPy
 FastAPI
 MongoDB
 React
 Tailwind
 Three.js
 GLSL
 Git
 GitHubOpenAI API (SSE)framer-motion